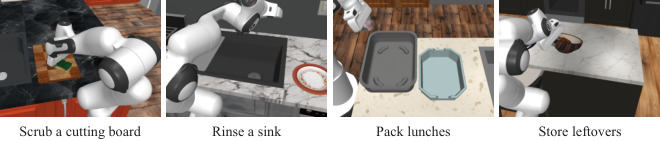
Robot learning can be limited by the tasks available in simulation before any policy is trained. Creating another environment requires choices about physics, rewards and what counts as success, and those choices can quietly simplify the real problem.
The October 29 Gym-Anything for Robotics preprint treats environment construction as a coding-agent task. Its creation-and-audit loop produces RoboWorld: 25 simulations, with 175 training environments and 25 test environments. The work includes ways to improve model performance through repeated experience and teaching signals. Primary source.
The simulator is part of the experiment
An automated author can create variety quickly. It can also introduce a reward shortcut or a physical interaction that is easier than its real counterpart. An audit therefore needs to challenge both the implementation and the definition of success.
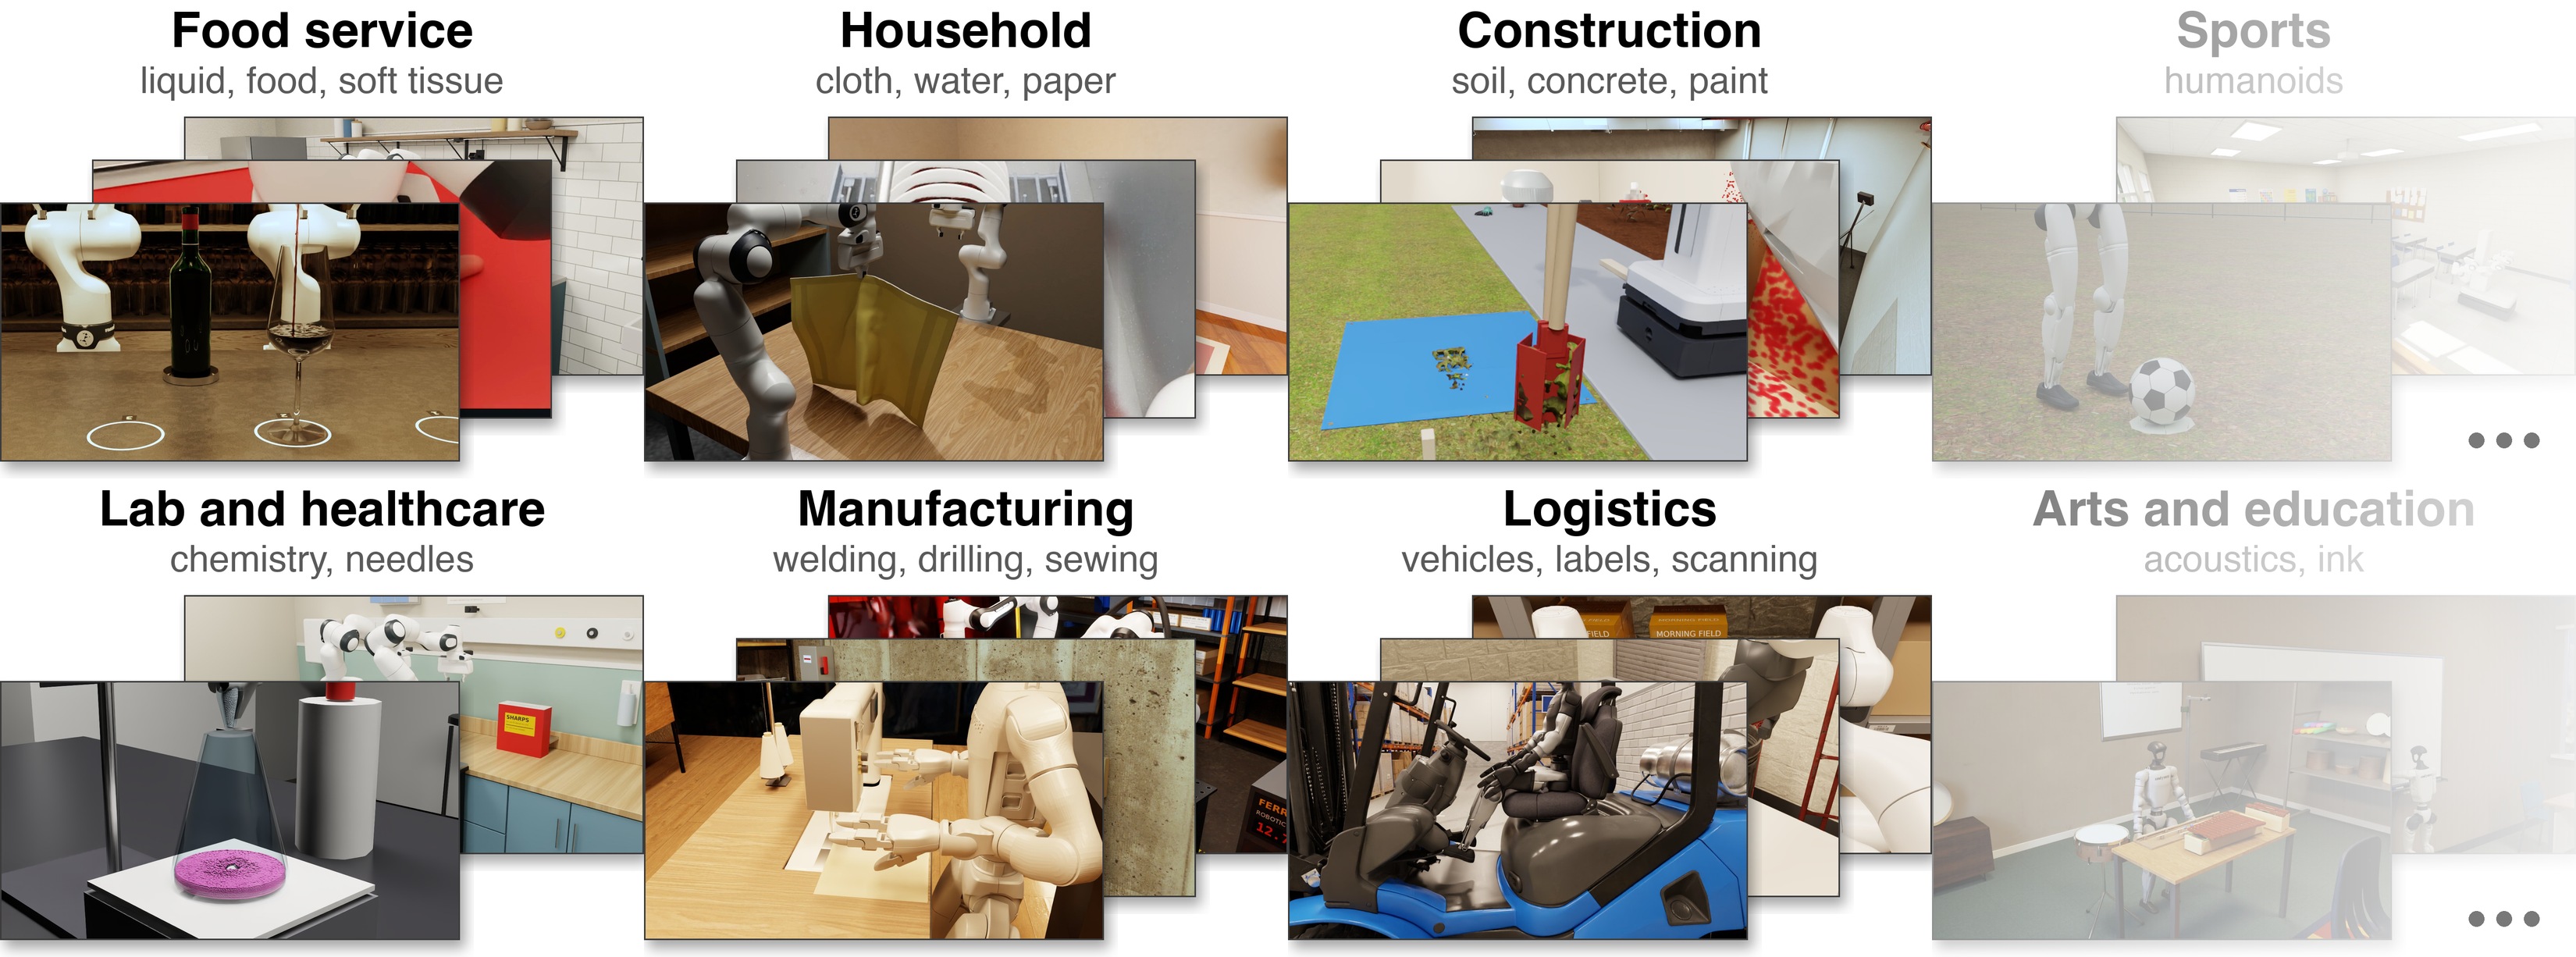
The authors select tasks using economic activity as a guide. That is a reason to study a task, not proof that success in its simulation creates commercial value. The collection remains a benchmark, not a fleet of robots performing those jobs.
Two kinds of progress should be measured separately
The immediate contribution is a reproducible route to building and testing environments. The next question is whether an independently specified task remains difficult for the right reasons after automated construction.
A useful follow-up would compare generated environments against measurements of matched physical tasks, then test transfer without changing the acceptance criteria after seeing failures. If fidelity improves alongside scale, automated construction could widen robot training coverage. A bigger task count alone cannot establish that outcome.
The source figure is reproduced unchanged under CC BY 4.0; attribution appears in the image caption.
Sources & evidence
Sources describe the announcements and evidence available when this analysis was published. Company claims are attributed; plans and trials are not treated as sustained operation.