Taking an instrument from a person is only part of a useful robotic handoff. The system must preserve the purpose of the action while the human releases it. For surgical retraction, losing that purpose means losing the held position even after a successful grasp.
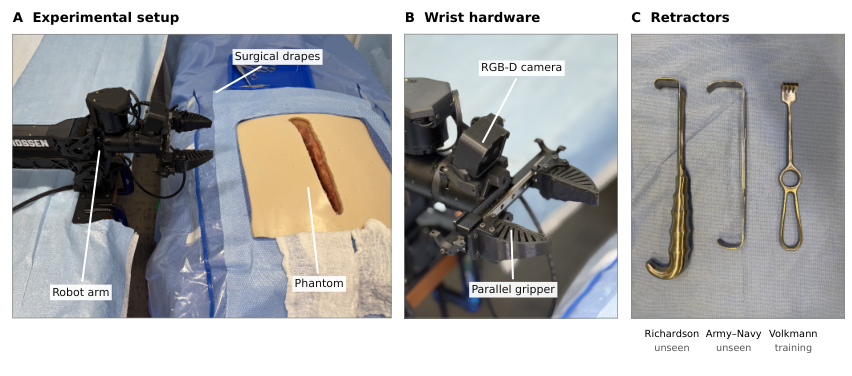
The October 28 SimRetract preprint studies this boundary using a robot arm trained on simulated demonstrations. In 50 surgeon-defined phantom presentations, the authors report a 90 percent grasp rate and a 78 percent rate of maintaining retraction at handoff, without real-world fine-tuning. Primary source.
The second score is the operational one
The distinction between grasping and holding is central. Reporting only the first would hide failures of the complete assistance task. These are phantom experiments, not patient outcomes or authorization for clinical use.
The system uses masked instrument images, grasp geometry and training situations that include deviations from the ideal approach. An ablation removing the instrument mask sharply reduces physical-test performance. That result points to the input representation as a substantial part of transfer, rather than attributing success to simulation volume alone. Primary source.
Transfer is a testable boundary
For robotic manipulation more broadly, the immediate lesson is to define success around the state left for the next actor. A handoff that forces a person to restore the working condition may erase the apparent benefit.
The next evidence should broaden instrument and presentation variation while documenting contact forces, unsuccessful handoffs and recovery. A larger, independent study would be needed before these bounded research results support a clinical deployment claim.
The source figure is reproduced unchanged under CC BY 4.0; attribution appears in the image caption.
Sources & evidence
Sources describe the announcements and evidence available when this analysis was published. Company claims are attributed; plans and trials are not treated as sustained operation.